
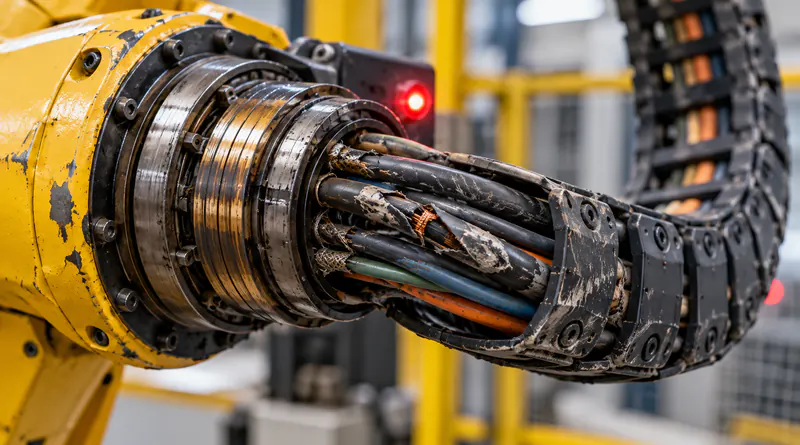
Cables that keep breaking
Slip rings and cable carriers wear out at rotating joints, causing intermittent faults that are hard to trace.
Robotics, Actuators & Motor Control
CRATUS engineers the electronics that make machines move: motor drives and actuator controllers, real-time control firmware, wireless links across moving joints, ROS 2 integration, and the AI that sees obstacles and predicts the next failure.
The challenge
Moving machines punish every weak point: cables flex, loads kick back, timing slips and people step into the workspace.
Slip rings and cable carriers wear out at rotating joints, causing intermittent faults that are hard to trace.
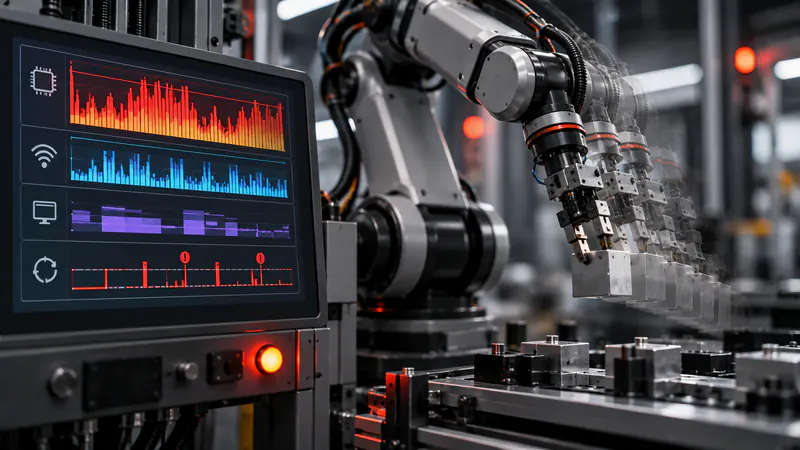
Loops that share a processor with communications and UI miss deadlines, and the motion shows it.
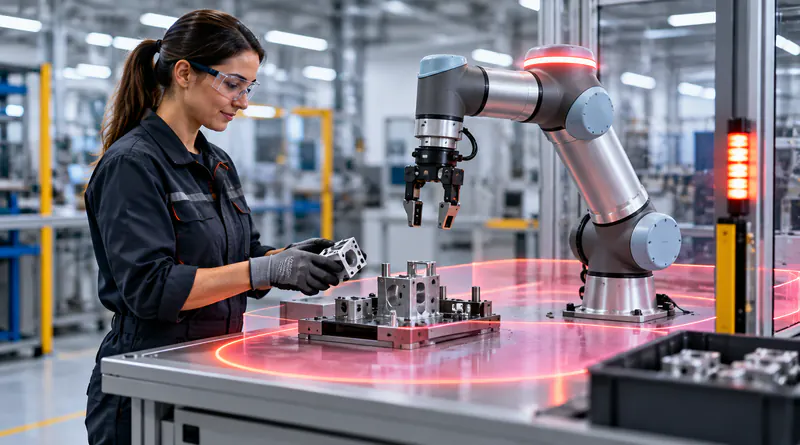
Robots that share space with people need protective stops that always work, and the intelligence to rarely need them.
CRATUS closes these gaps at every layer — hardware, firmware, software and AI, engineered by one team.
See our approachOur approach
Smooth, safe motion comes from hardware and firmware designed together: current sensing matched to control-loop timing, protection matched to the load, and software that makes all of it visible.
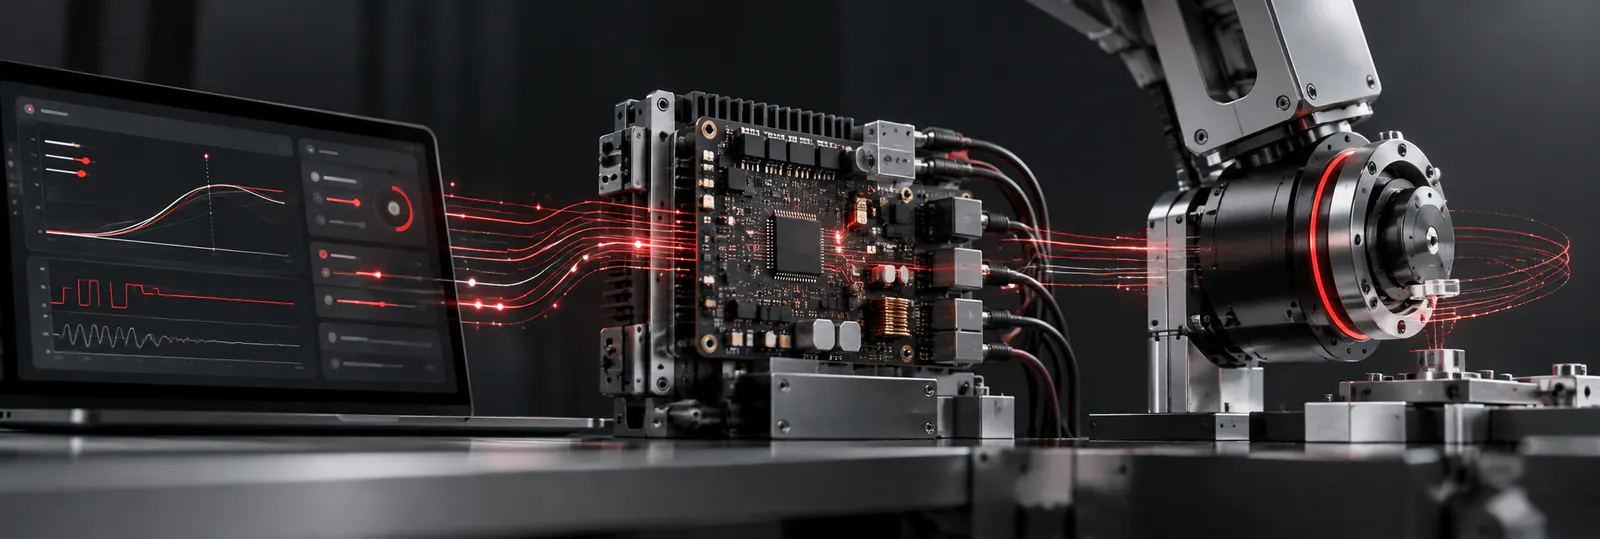
BLDC/PMSM, stepper and brushed DC drives; solenoid, valve and brake drivers; gate drivers; shunt and Hall current sensing; encoder and resolver interfaces; regenerative energy handling; and compact actuator boards that fit your mechanics.
Field-oriented control with sensored or sensorless commutation, cascaded torque, velocity and position loops, motion profiles, homing, stall and over-current protection, CAN FD and CANopen nodes, and safe over-the-air updates.
ROS 2 drivers and nodes for custom hardware, commissioning and tuning GUIs, telemetry dashboards, fleet monitoring, and simulation so software can be tested before hardware exists.
Edge AI on NVIDIA Jetson-class computers for LiDAR and camera perception, motor-current and vibration signatures for predictive maintenance, and anomaly detection on every cycle the machine runs.
What we execute
New robot platforms, custom actuators, or a retrofit that makes an existing machine smarter.
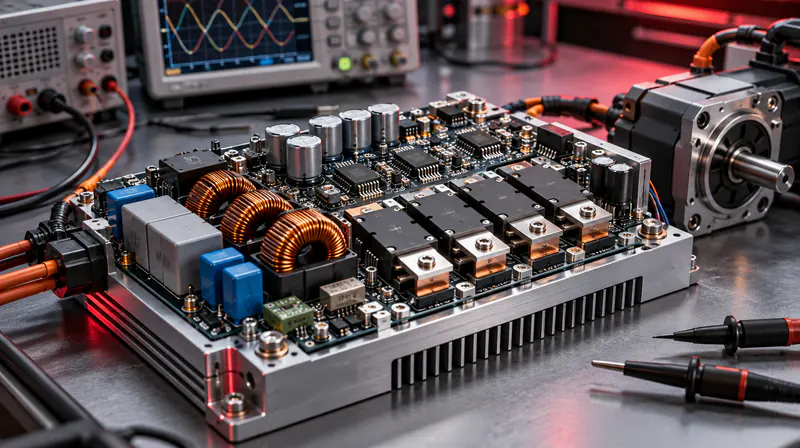
Three-phase inverters and gate drivers, current sensing, protection, thermal design and EMC filtering for battery-powered and line-powered machines.
Hardware
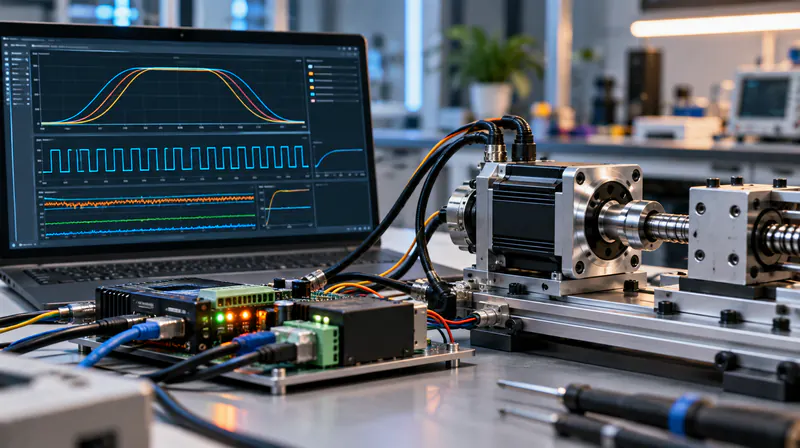
FOC with space-vector PWM, cascaded control loops, S-curve trajectories, encoder and resolver interfaces, auto-tuning, and loop timing measured on real hardware.
Firmware
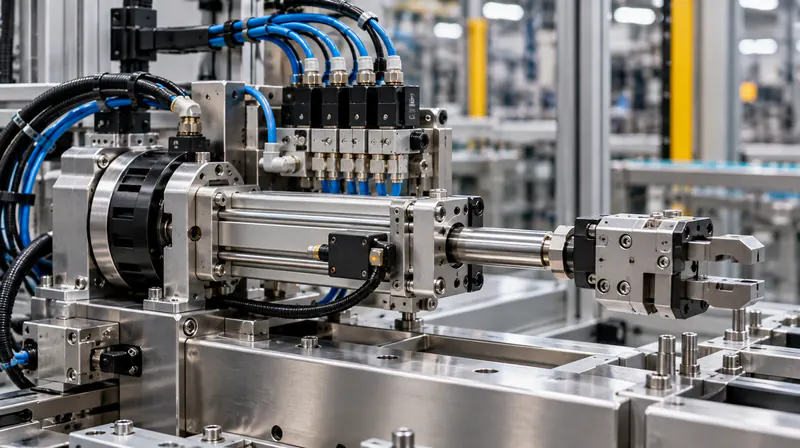
Drivers for solenoids, valves, grippers, linear actuators and brakes, with inductive-load protection, peak-and-hold current control and position feedback.
Hardware · Firmware
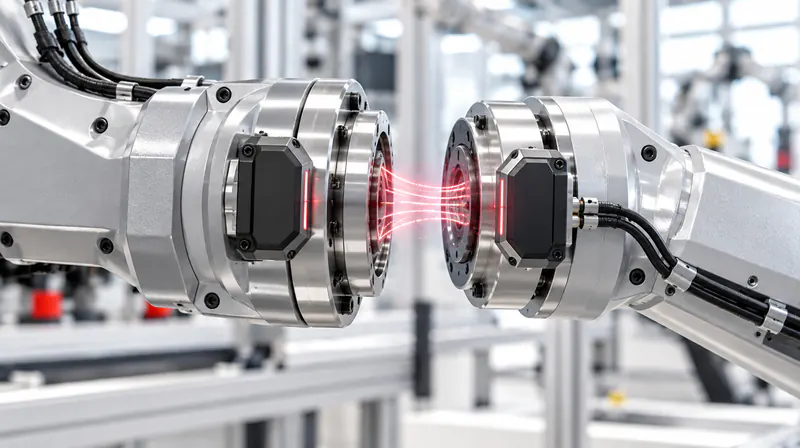
The INTERCAL8 ICL8-WC182 carries dual CAN FD over wireless links across rotating and moving joints, removing data slip rings and fragile cable carriers.
Hardware · Firmware
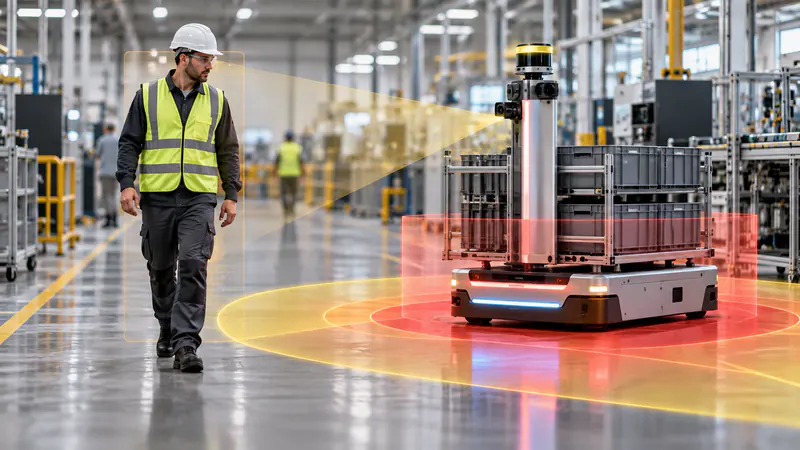
Safety-rated LiDAR, vision and people-detection zones for speed-and-separation monitoring and protective stops, built with our LiDAR and perception team.
Hardware · Software · AI
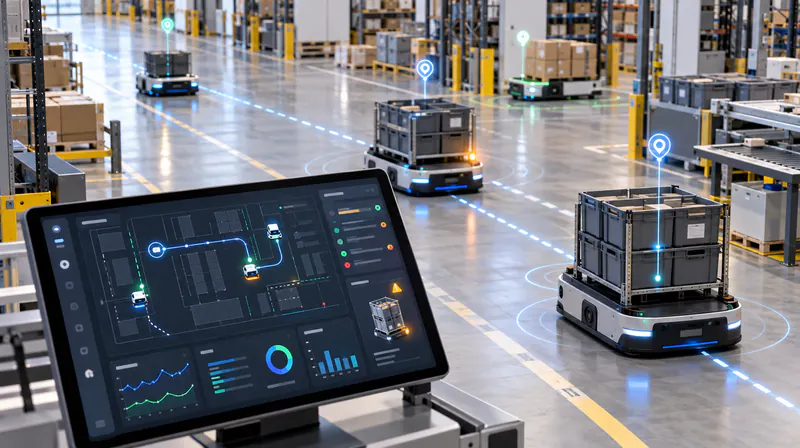
ROS 2 integration, mission and telemetry back ends, UWB real-time location for centimeter-level positioning, OTA updates and AI predictive maintenance across a fleet.
Software · AI
INTERCAL8 LOMA & related products
LOMA Load Managers bring electronic circuit breaker (ECB) technology to machine power, with inductive-load protected channels, programmable trips and per-channel monitoring. They are controlled over MODBUS, J1939, CANopen or proprietary Wireless CAN. Paired with INTERCAL8’s wireless CAN FD and thermal products, they simplify both power and data on moving machines.
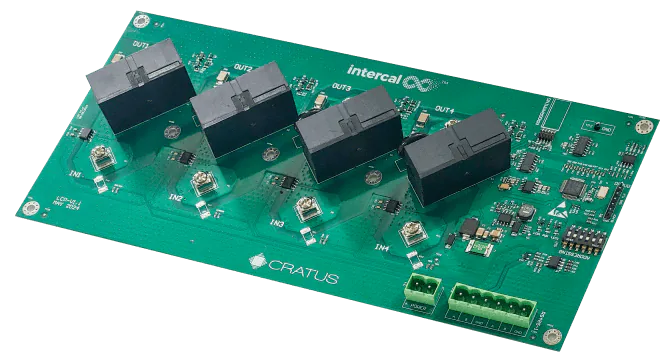
AI-Enabled Electronic Circuit Breaker
Protects and sequences motor, solenoid and brake circuits on four inductive-load protected channels. Sheds low-priority loads when a battery sags, with no breaker resets in the field.
Product details for ICL8-LC574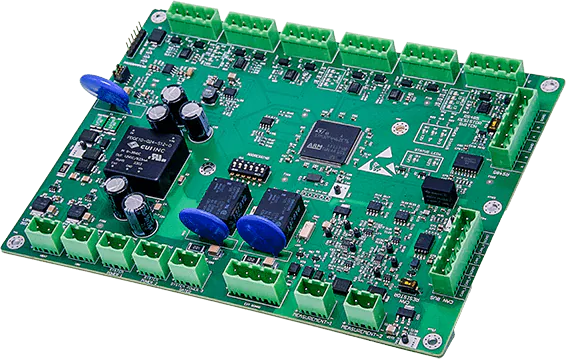
Isolated DC Power Controller
Uses integrated ideal diodes to hand off seamlessly between battery and dock or charger power on mobile robots. Remotely resets or powers off DC subsystems.
Product details for ICL8-PC548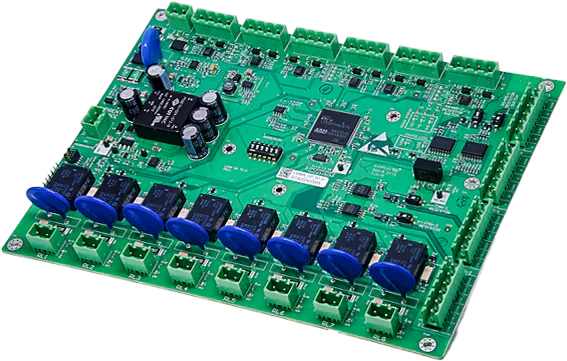
General-Purpose Load Controller
Isolated digital I/O and dual RS-485 & CAN for locks, beacons, indicators and contactors around a robot cell.
Product details for ICL8-GP515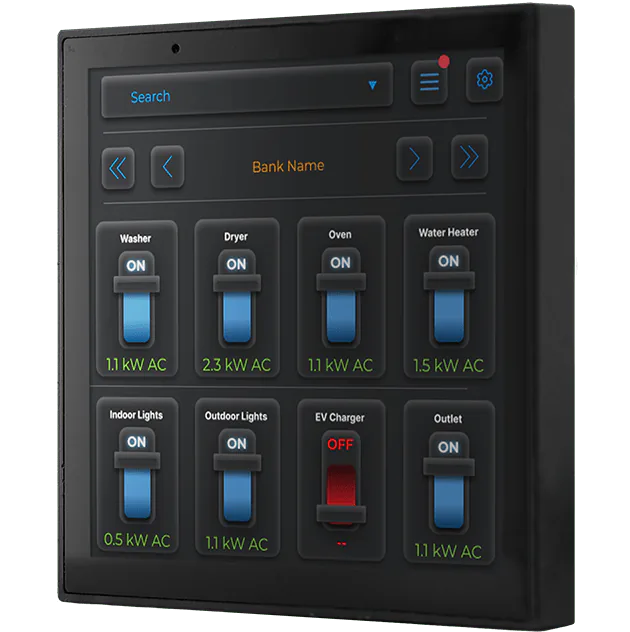
Multifunction Display & System Controller
Cell-side touchscreen for power states, manual overrides and algorithmic control of every LOMA channel.
Product details for ICL8-EB104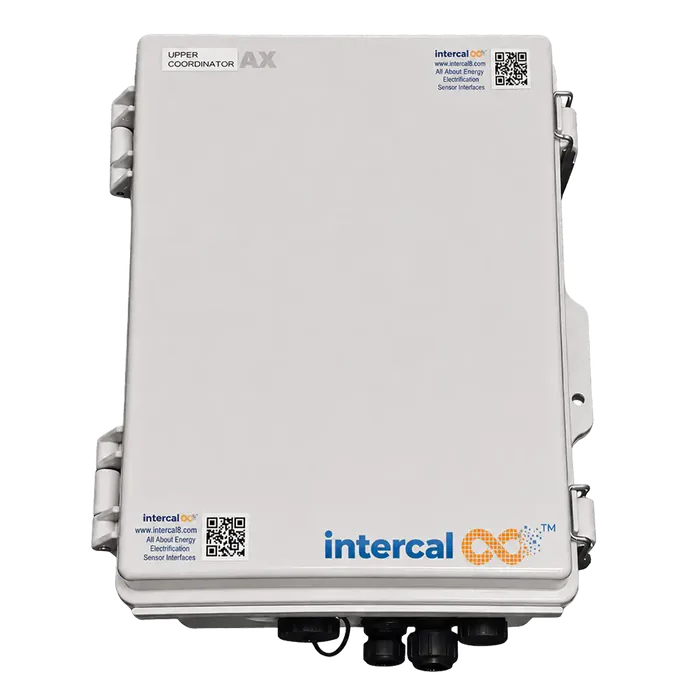
Wireless Dual CAN FD Control Board
Wireless dual CAN FD across rotating and moving joints, replacing separate gateways, radios, power supplies and protocol bridges.
Product details for ICL8-WC182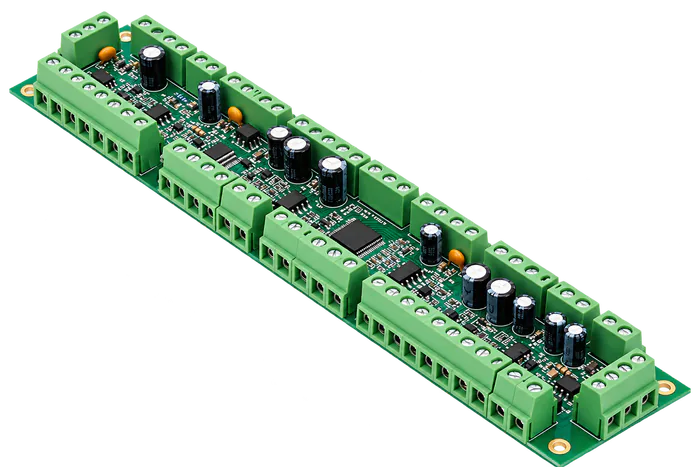
AI-Enabled 16-Channel Temperature Transmitter
Monitors motor, drive and battery temperatures on 16 channels and predicts thermal failures with on-device AI.
Product details for ICL8-TM116AI built in
Manage INTERCAL8 power hardware in plain language. Ask for channel status, balance the system, or set a rule such as “shed non-critical loads when consumption crosses a threshold” — no code required.
Explore LOMAWhen the battery drops below 20%, turn off the beacon and the tool heater.
Rule saved. Channel 3 (beacon) and channel 4 (tool heater) will power off below 20% battery. Drive and brake circuits stay on.
How we work
CRATUS works as a Team-in-a-Box. Hardware and firmware are built together, so timing is optimized, latency is lower and iterations are faster, with no hand-off delays between vendors.
Requirements, constraints, target standards and success metrics captured on one page you sign off.
Partition hardware, firmware, software and AI; pick key components; review risk and BOM cost early.
Schematics, PCB layout, firmware bring-up and first working units, designed with the mechanics in mind.
Bench, hardware-in-the-loop, fault-injection, environmental and EMC pre-compliance testing, with reports you can hand to a lab.
DFM/DFT, test fixtures, pilot builds, production support, over-the-air updates and lifecycle engineering.
Standards we engineer to
We design drives, controls and robot electronics to the machinery and robot-safety standards your customers and integrators will check against.
Certification is issued by accredited third parties such as TÜV, UL or exida. CRATUS engineers, documents and pre-tests to the standard and supports your assessment; we don’t self-certify.
FAQ
What robot builders and machine OEMs ask us most about drives, actuators and connected motion, across hardware, firmware, software and AI.
Still have a question? An engineer will answer it directly.
Ask an engineerAutonomous mobile robots and AGVs, robot arms and cells, gantries and positioning stages, automated tools and test equipment, and cranes and heavy machinery. We build new designs and retrofit existing machines with sensing, connectivity and safety.
Yes. CRATUS also offers industrial and mechanical design and prototyping, so the electronics are designed together with the enclosure, thermal path and cable routing. You work with one Team-in-a-Box instead of three vendors.
BLDC and PMSM, stepper and brushed DC motors, plus solenoids, valves, grippers, linear actuators and brakes. We cover everything from low-voltage battery systems to higher-voltage industrial drives, scoped per project.
With wireless CAN. The INTERCAL8 ICL8-WC182 combines dual CAN FD channels, dual wireless links, 9–36 V input, galvanic isolation, ESD protection, an industrial temperature rating, hardware node addressing and OTA firmware updates on one board. It replaces separate gateways, radios, power supplies and protocol bridges.
Power still needs a path across the joint, so we design that too: a power-only slip ring, inductive power transfer or a local battery.
With clamps and TVS protection sized to the load, brake-chopper dissipation or regeneration back into the battery, DC-bus capacitor sizing and over-voltage monitoring. For switched loads, the LOMA ICL8-LC574’s channels are inductive-load protected.
Yes. We implement FOC with space-vector PWM using encoders, Hall sensors or resolvers, or sensorless observers when cost or packaging require it. We tune current-loop bandwidth to your motor and load, and provide tuning tools so your team can adjust gains in the field.
Current loops run in hardware-timed interrupts on Arm Cortex-M class MCUs, or on a DSP or FPGA when the bandwidth calls for it. Communications and UI run on a separate core or processor. We measure loop jitter and latency on real hardware.
We implement drive safety functions in line with IEC 61800-5-2. Safe Torque Off (STO) removes gate-drive energy through an independent hardware path. SS1 and SS2 bring the axis to a monitored, controlled stop, then either remove torque or supervise standstill. Brakes are controlled and tested. See our Functional Safety & Failsafe Electronics page for the full approach.
Yes. We write ROS 2 drivers and nodes for custom hardware, bridge CAN and CAN FD networks into ROS 2 topics, integrate navigation and manipulation stacks, and set up simulation so software can be tested before the hardware is ready.
Yes. We add sensors and telemetry gateways and connect them through ASSET-Rx EDGE, CRATUS’s no-code/low-code edge middleware. You get dashboards and alerts for utilization, faults and maintenance.
Three places. Perception detects people, vehicles and obstacles from LiDAR and cameras on Jetson-class hardware. Predictive maintenance uses motor-current signatures, vibration and temperature. Anomaly detection watches cycle times and forces. CRATUS also builds the annotated and ground-truth datasets these models need.
No. Protective stops rely on safety-rated sensors, such as safety-rated LiDAR, and deterministic logic. AI makes the machine more productive around that, for example by anticipating path conflicts and slowing early so the protective stop is rarely needed.
Yes. The INTERCAL8 AI Assistant lets operators query and manage LOMA power hardware in natural language. For example, they can see which loads are drawing the most or shed non-critical loads during peak demand.
Send us a message through our contact form with what you’re building, where it will operate and your timeline. We’ll schedule a technical discovery call, then send a scoped, phased proposal, so you can begin with an architecture study or prototype and commit to production later.
Yes. We can own the whole system as a Team-in-a-Box, or take a defined piece (the power stage, the firmware, the cloud pipeline, the AI model) and work inside your repositories, toolchains and design reviews.
Yes. We carry designs from prototype through DFM and DFT reviews, test-fixture and end-of-line test development, pilot builds and full-scale production support.
Yes. Many projects start with a bench demonstrator or a single retrofitted machine. That de-risks the control approach and the business case before you commit to a production design.
Talk to a CRATUS engineer
Share the motor, load, duty cycle and environment, or the machine you want to make smarter. A CRATUS engineer will reply with questions, an architecture and a phased plan.
Contact UsKeep exploring
Talk to our team about your facility, and let’s design a system that fits your risks and goals.
Request a Solution BriefInterested ?
We would be pleased to send you detailed information about our products or services.
Simply enter your details in the contact form below and we will get in touch with shortly.
CRATUS respects your personal information and keeps it safe. By sending this form, you consent to allow CRATUS to store and process your personal information as stated in our Privacy Policy.
GET IN TOUCH
One of our experts will be communicating with you shortly. We are committed to understanding your application and providing support, tailored to your specific requirements.