








Browse our products by end market and application. Each panel groups use cases by product, with a side-by-side specification comparison across manufacturers.
Selecting a sensor for this market requires prioritizing an ultra-wide field of view, short-range blind-spot mitigation, and short-range safety coverage to support dynamic collision avoidance in high-vibration industrial environments. These LiDAR systems are used where robots, forklifts, AGVs, AMRs, people, and production equipment operate in close proximity.
| Sensor | Scan type | Vertical channels | Horizontal channels | FOV — horizontal | FOV — vertical | Range @10% | Minimum range | Accuracy | Weight | Power | Protection | Temperature range |
|---|---|---|---|---|---|---|---|---|---|---|---|---|
| RoboSenseFairy | Mechanical | 48 | 1440 | 360° | 31.68° | 80 m | ≤0.2 m | 0.5 cm (1σ) | <350 g | <10 W | IP67 / IP6K9K | -40 °C to +60 °C |
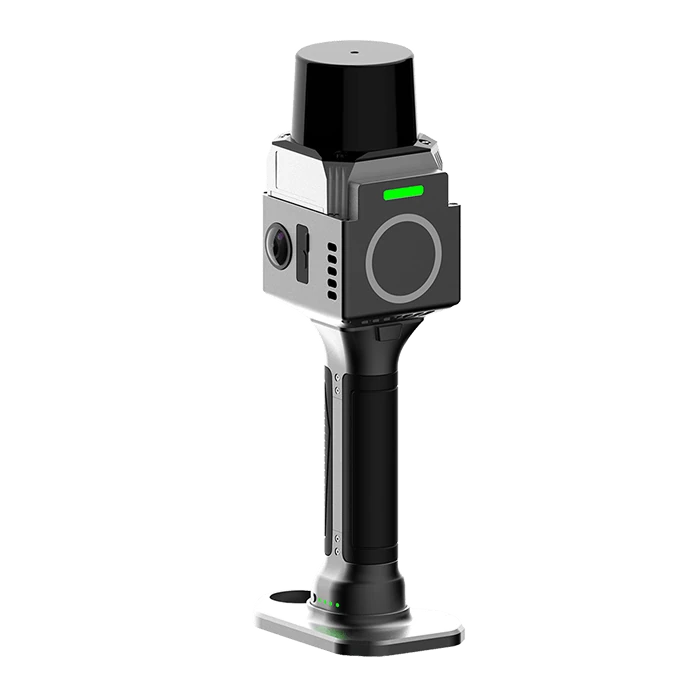
| SXSXMCA Lite | Handheld SLAM | 181-eq | 2400 | 360° | 65° | 40 m | 0.05 m | 8 mm relative / 5 cm absolute | 760 g main / 1,123 g with battery | <20 W | IP5X | -20 °C to +55 °C |
| HESAIXT16 | Mechanical | 16 | 2000 @10 Hz | 360° | 30° | 80 m | 0.05 m | ±1 cm | 800 g | 9 W | IP6K7 | -20 °C to +65 °C |
| HESAIXT32M1X | Mechanical | 32 | 2000 @10 Hz | 360° | 31° | 80 m | 0.05 m | ±1 cm | 800 g | 10 W | IP6K7 | -20 °C to +65 °C |
| HESAIXT32M2X | Mechanical | 32 | 2000 @10 Hz | 360° | 40.3° | 80 m | 0.5 m | ±1 cm | 490 g | 10 W | IP6K7 | -20 °C to +60 °C |
| SXSXC01 | Non-repetitive | 181-eq | 1200-eq @1 s / 2400-eq @2 s | 360° | 65° | 40 m | 0.05 m | <1 cm @10 m (1σ, 80% target) | 420 g | 15 W | IP67 | -20 °C to +55 °C |
| RoboSenseAiry | Mechanical | 96 | 900 @10 Hz | 360° | 90° | 30 m | 0.1 m | 1.5 cm (1σ) | 230 ±20 g | 8 W | IP67 / IP6K9K | -40 °C to +60 °C |
| HESAIFTX 140 | Solid state | 192 | 256 | 140° | 105° | 30 m | 0.1 m | ±2 cm | ~160 g | <6 W | IP6K7 / IP6K9K | -40 °C to +85 °C |
| HESAIFTX 180 | Solid state | 192 | 216 | 180° | 140° | 20 m | 0.05 m | ±2 cm | ~180 g | <6 W | IP6K7 / IP6K9K | -40 °C to +85 °C |
| SEYONDHummingbird D1-R | Solid state | 192-eq | 255 | 140° | 100° | 30 m | 0.1 m | ±2 cm | 220 g | 6 W | IP67 / IP69K | -40 °C to +60 °C |
| SEYONDRobin W | Semi-solid-state | 192 lines | 800 | 120° | 70° | 70 m | 0.1 m | ±2 cm | 800 g | <7.2 W | IP67 body / IP69K window | -40 °C to +85 °C |
| ONX | Solid state | 56-eq | 192 | 57.6° | 16.8° | 50 m | 0 m | ±2.9 cm | 1.3 kg | 15–23 W | IP65 | 0 °C to +45 °C |
| HESAIJT16 | Mechanical | 16 | 600 @10 Hz | 360° | 40° | 30 m | 0.1 m | ±3 cm | 200 g | 4.3 W | IP6K7 / IP6K9K | -20 °C to +55 °C; 0 °C to +55 °C @10 Hz |
| HESAIQT128 | Mechanical | 128 | 900 @10 Hz | 360° | 105° | 20 m | 0.05 m | ±3 cm | 700 g | 12 W | IP6K7 / IP6K9K | -40 °C to +85 °C |
| HESAIJT64P | Mechanical | 64 | 900 @10 Hz | 360° | 95° | 20 m | 0 m | ±3 cm | 265 g | 7.6 W | IP6K7 | -20 °C to +65 °C |
| 3DMODIN1 Lite | Solid state | 180-eq | 240 | 120° | 90° | 25 m | 0.15 m | ±3 cm | 274 g | 11 W | IP66 | -20 °C to +65 °C |
| 3DMONO | Solid state | 180-eq | 240 | 120° | 90° | 30 m | 0.2 m | ±3 cm | 280 g | 11 W | IP67 | -20 °C to +55 °C |
| HESAIFT120 | Solid state | 120 | 160 | 100° | 75° | 22 m | 0.1 m | ±5 cm | 700 g | <15 W | IP6K7 / IP6K9K | -40 °C to +85 °C |
| HESAIJT128 | Mechanical | 128 | 900 @10 Hz | 360° | 189° | 40 m | 0 m | ±5 cm | <250 g | 9.5 W | IP6K7 | -20 °C to +65 °C |
| RoboSenseE1 | Fully solid-state (Flash, 2D electronic) | 144 | 192 | 120° | 90° | 30 m | 0.1 m | ±5 cm (1σ) | 330 ±20 g | <10 W | IP67 / IP6K9K | -40 °C to +85 °C |
| RoboSenseE1R | Solid state | 144-eq | 192 | 120° | 90° | 30 m | 0.1 m | ±5 cm (1σ) | 330 ±20 g | <10 W | IP67 / IP6K9K | -40 °C to +85 °C |
| RoboSenseEMX | Digital scanning | 192 | N/A (0.08° H resolution) | 120° | 20° | 200 m | 1.5 m | ±5 cm (1σ) | 500 ±20 g | 10 W | IP67 / IP6K9K | -40 °C to +85 °C |
| SEYONDRobin E1X | Semi-solid-state | 96 lines (192 super-res) | 1200 | 120° | 20° | 200 m | 1 m | ±5 cm | 470 g | 6.3 W | IP67 body / IP69K window | -40 °C to +85 °C |
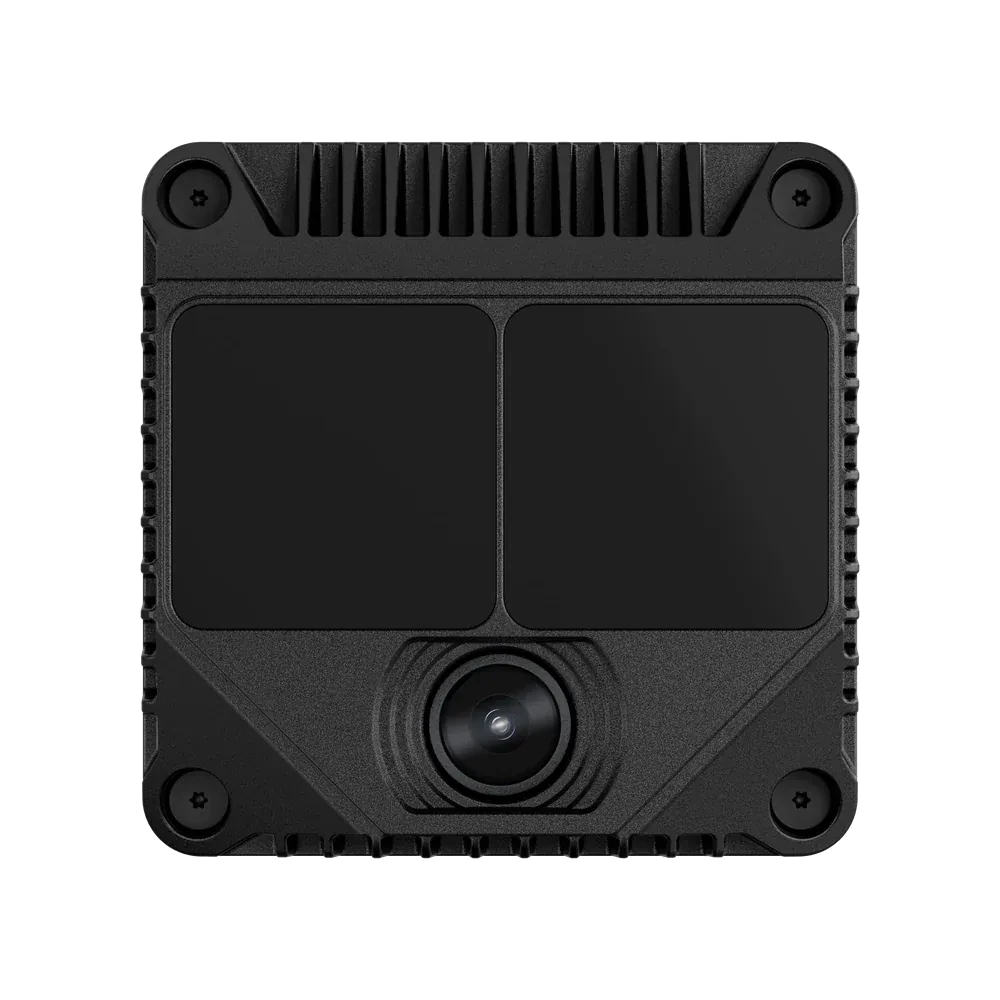
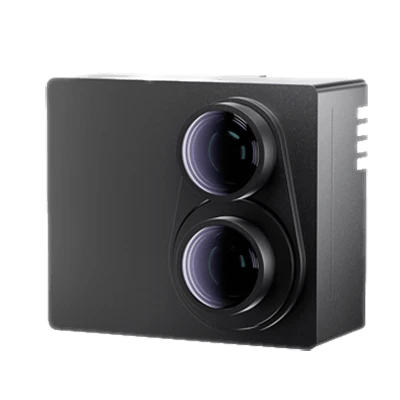
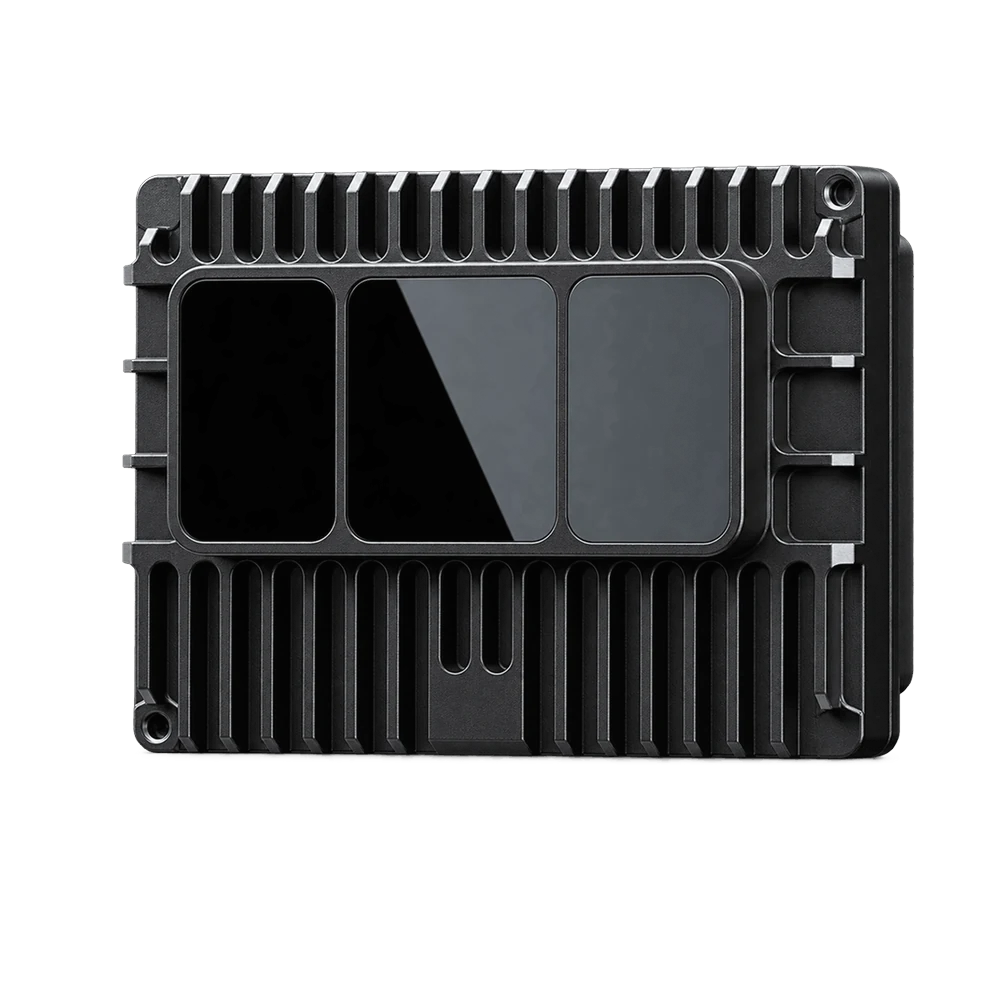
Compact dToF depth sensor, global-shutter RGB camera and IMU with built-in SLAM and spatial memory. Built for embodied AI agents on quadruped, humanoid and mobile robot platforms.
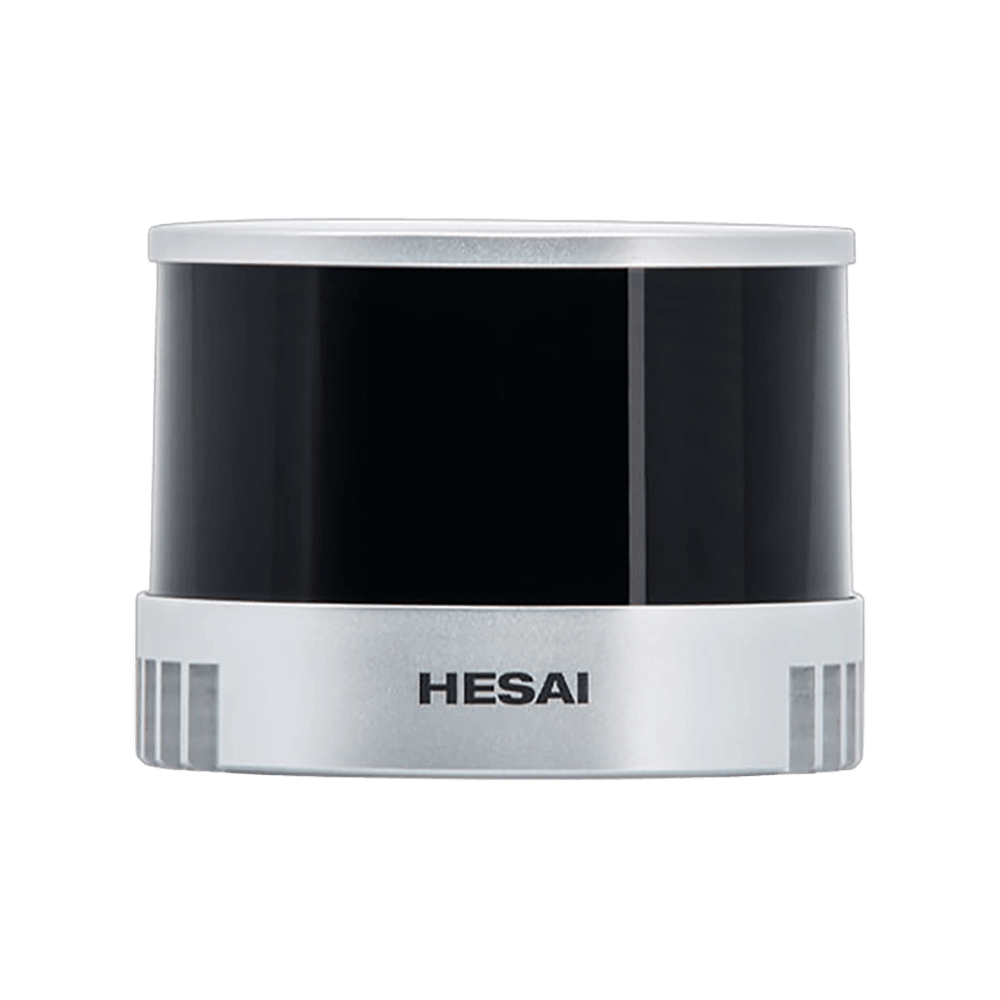
Mini 360° x 189°
Hyper-Hemispherical 3D Lidar
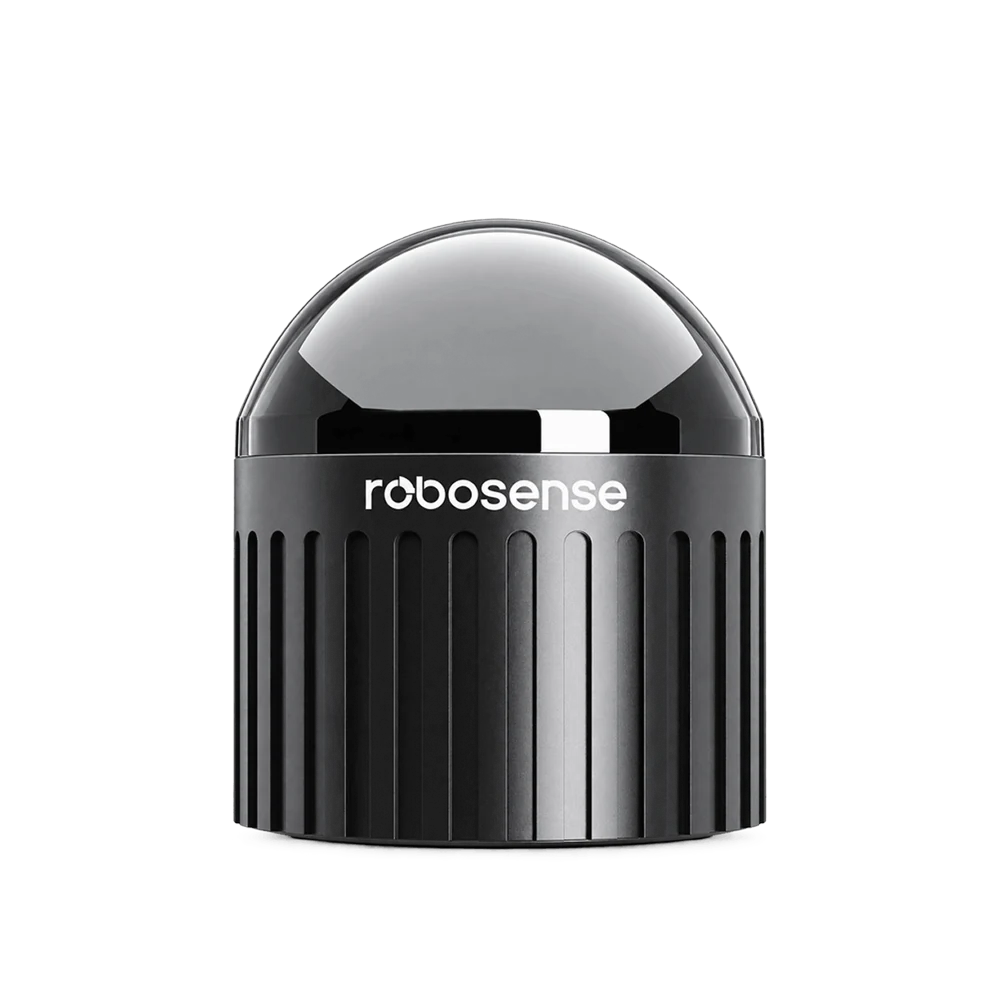
A full 360° × 90° hemisphere of perception from a body the size of a ping-pong ball, about 860,000 points per second at 1.5 cm precision and a dense point cloud using under 8 watts. Ideal for industrial automation and robotics navigation needing 360° perception.
The world’s first industrial 3D safety LiDAR. A quasi-hemispherical protective and warning zone built to PL d, SIL 2 and Type 3, with two independent safety channels — and a high-beam-count 3D point cloud for navigation from the same unit. One sensor where AMRs, AGVs and autonomous forklifts used to need a 2D safety scanner plus a navigation LiDAR.
Ultra Compact, Wide Field of View, Short Range, Power Efficient LiDAR for Near Field Sensing, Robotics, Smart Infrastructure and Industrial Automation Use Cases
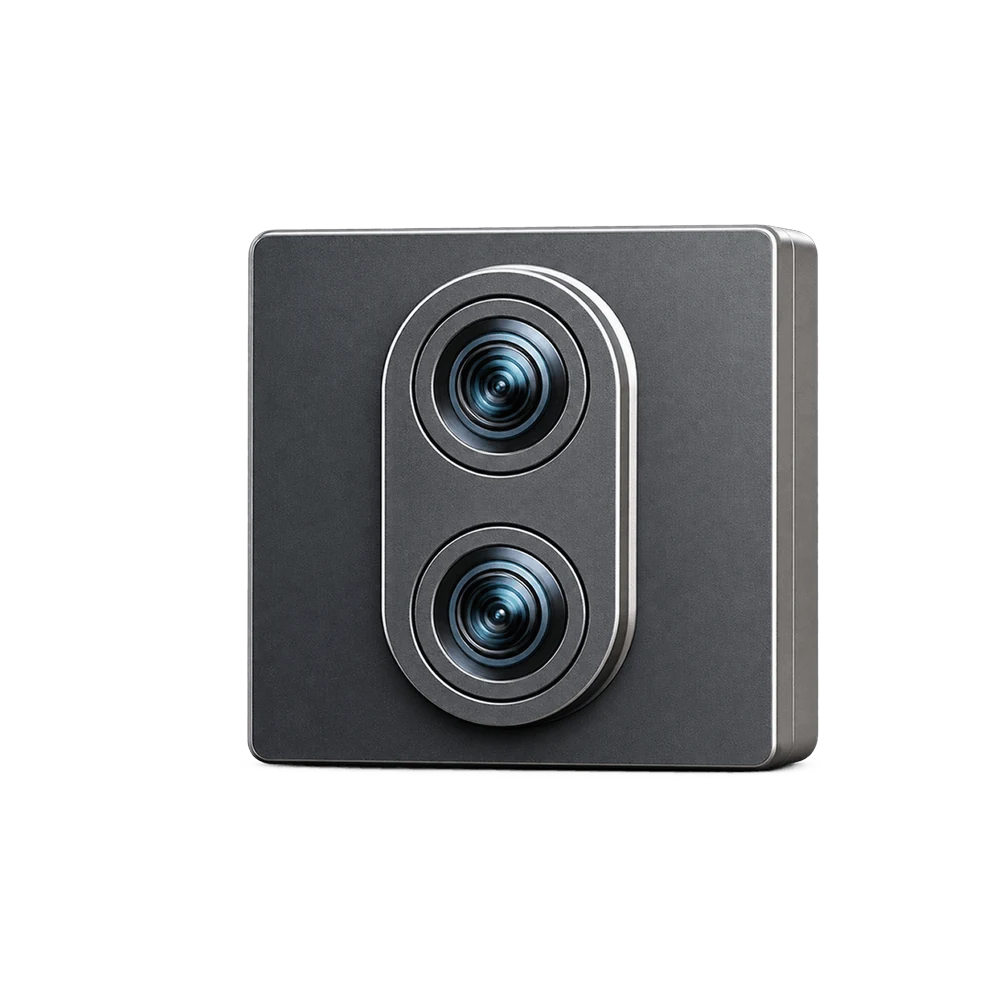
Highly Integrated functions camera, IMU, spatial memory and built-in mapping, Ideal for AMR, Humanoid, industrial machinery and safety applications
Automotive-Grade Fully Solid-State 140°
Short-Range Lidar
Automotive-Grade Fully Solid-State 180°
Short-Range Lidar
Solid-state directional flash LiDAR with proprietary chips and a 120° × 90° ultra-wide field of view that scans the near-field blind spot in automotive, robotics and industrial automation applications requiring near-field detection for safety and access monitoring.
Compact solid-state LiDAR with dense point cloud data and up to 140 m detection range for advanced automation applications.
0.5 cm precision at up to 150 metres, 96 beams and 1.37 million points per second of point cloud density, in a lightweight lidar weighing under 350 grams.
32-Channel 360° Spinning Mid-Range Lidar
High Precision. Minimum Range of Zero. Cost Efficient
The automotive grade E platform, redesigned for robots: a 120° × 90° field of view, 75 m of reach and 144 structured beams from a flat, flush window with no moving parts.
Real 192 beams, 300 m range and a 20 Hz frame rate in a 120 × 80 × 30 mm body.
180° × 135° field of view directional lidar sensor with 1 cm high precision, 1.5 million points per second and no moving parts, for robotics and industrial automation applications such as robot navigation, collision avoidance, object counting, people counting and access security.
Compact 360° × 95° mechanical scanning 3D LiDAR
High Precision Special Scanning for AEC Applications
<1 cm Accuracy · 360° Scanning · Real-Time, Ready-to-Use Point Clouds
Mini 360° x 40° 3D Lidar
Designed for Robotics and Industrial Applications
32-Channel 360° Spinning Mid-Range Lidar
High Precision. Minimum Range of Zero. Cost Efficient
High performance for passenger and commercial vehicles under highway conditions
Mid Range, compact, affordable solution for general purpose autonomy
GET IN TOUCH
One of our experts will be communicating with you shortly. We are committed to understanding your application and providing support, tailored to your specific requirements.
Request a Quote
One of our experts will be communicating with you shortly. We are committed to understanding your application and providing support, tailored to your specific requirements.